Projects
Research on haptics, robotics, and human-computer interaction, newest first.
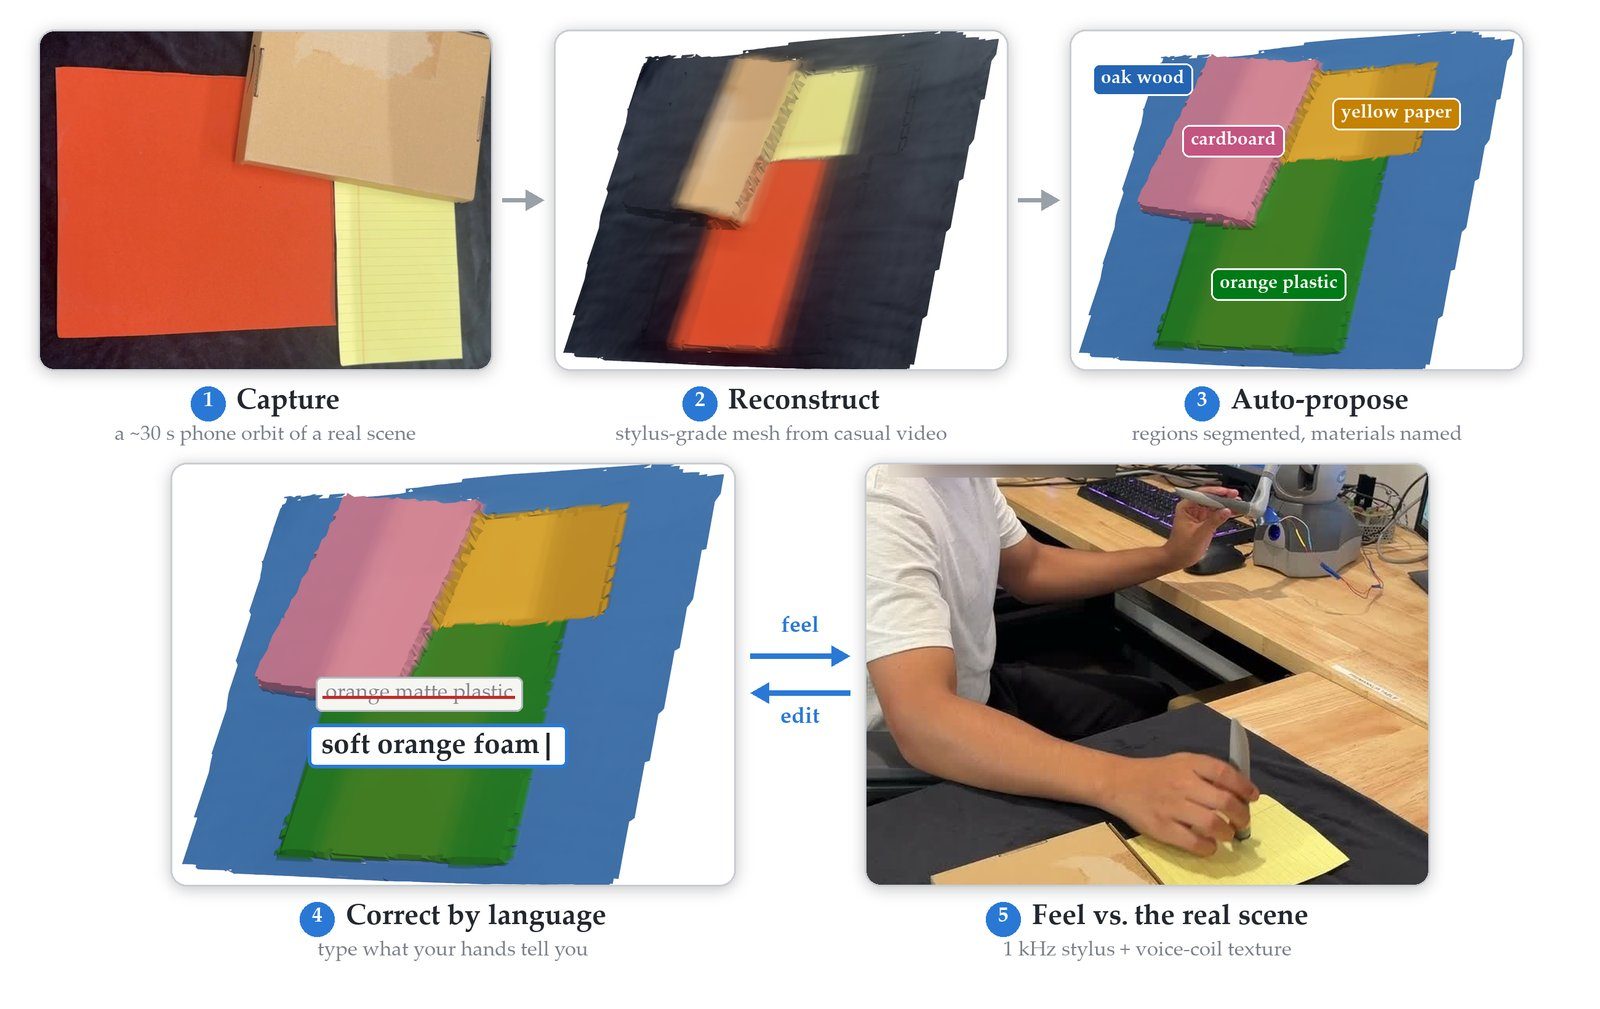
TouchTwin
Turn a 30-second phone video into a touchable twin, then fix what feels wrong by typing what your hand tells you.
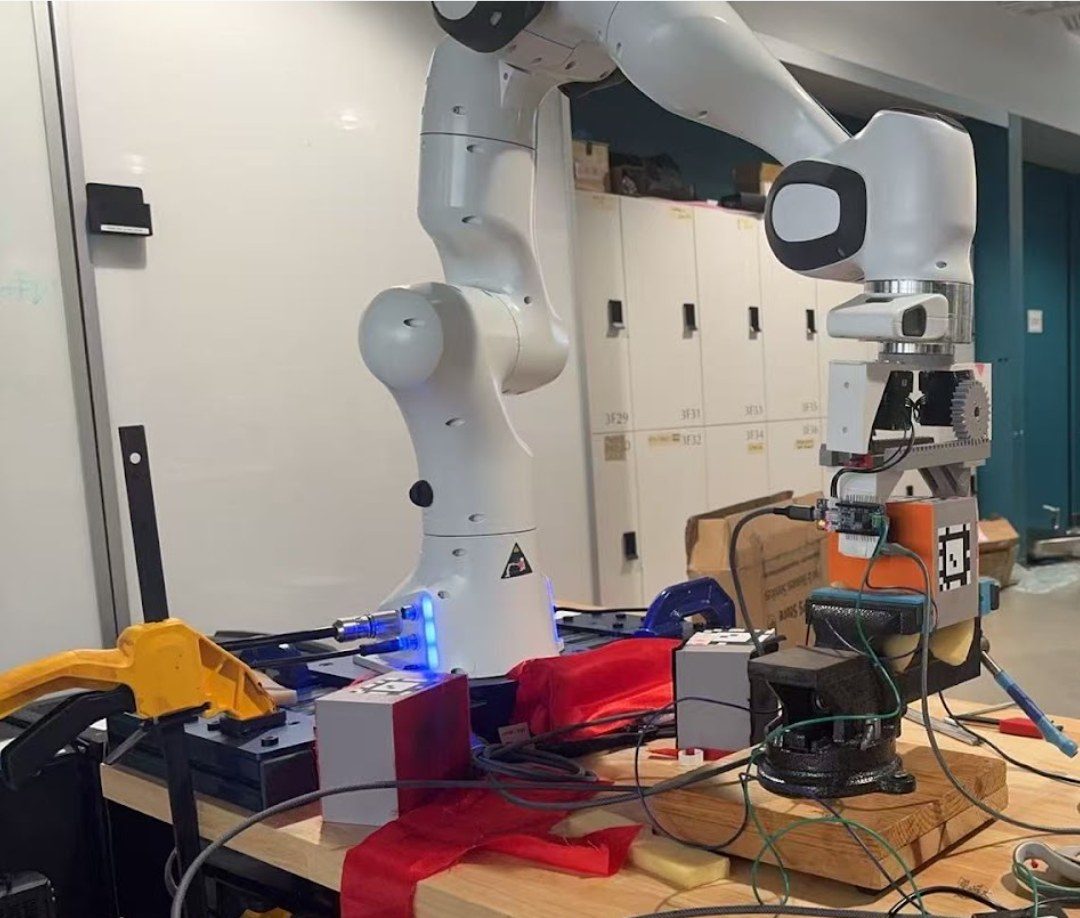
Feeling What the Robot Touches
Estimating contact from tactile video and force, and rendering it to the operator's hand during teleoperation.
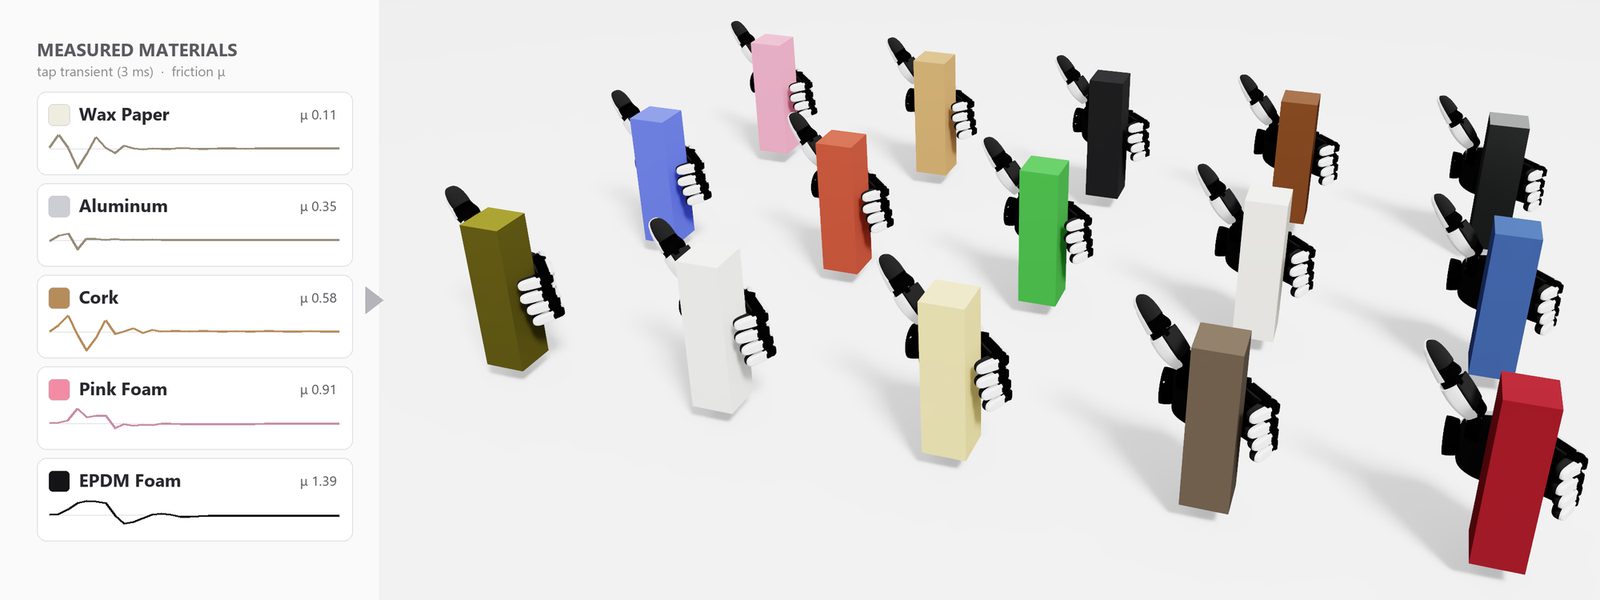
Physically Grounded Material Diversity
Putting measured materials, not random friction values, into simulation, so robot hands learn how real surfaces grip, slide, and slip.
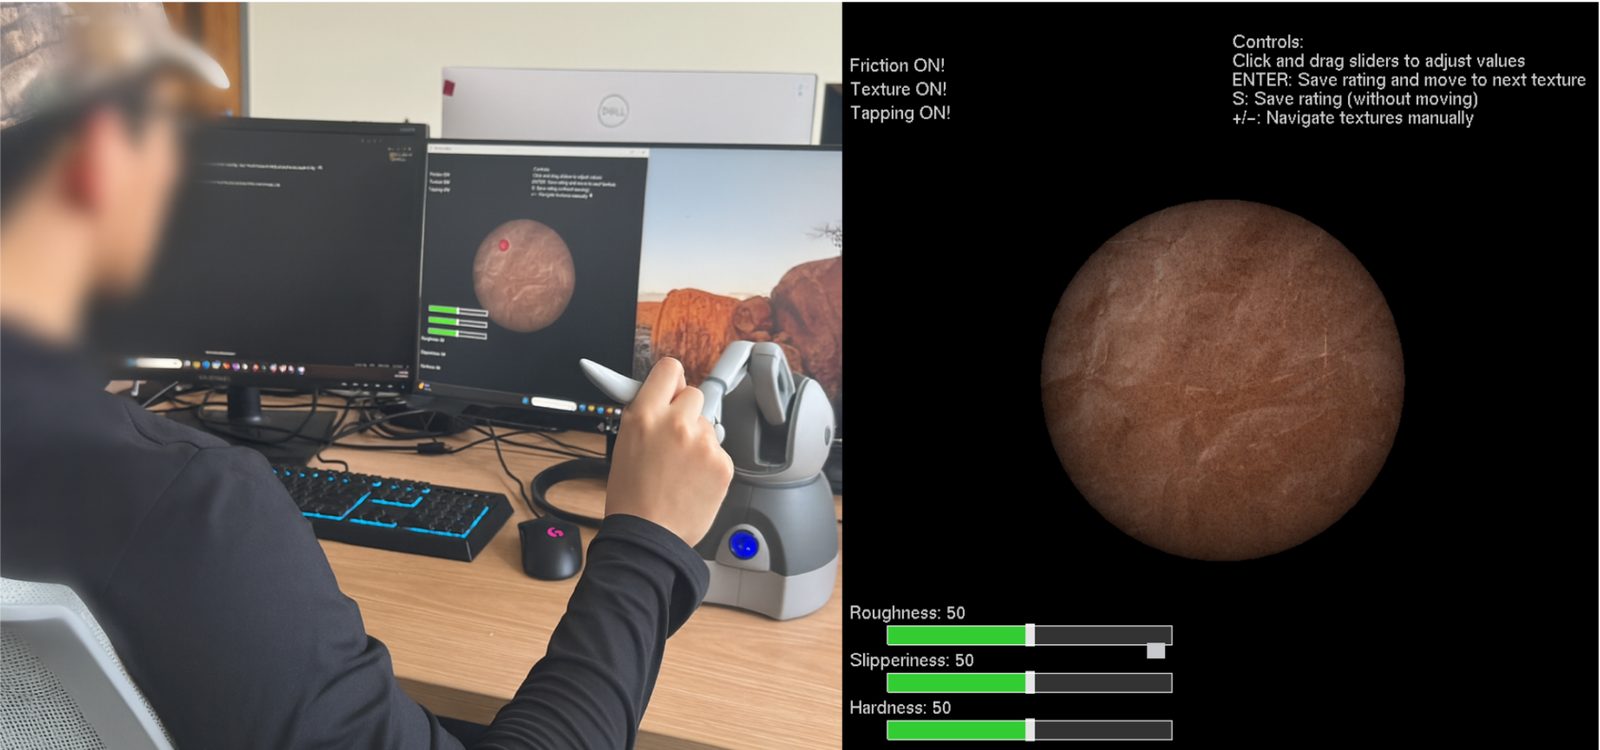
Language-Guided Multimodal Texture Authoring
Type “gritty but cushioned” and feel it: one prompt generates sliding vibration, tapping, and a matching visual.
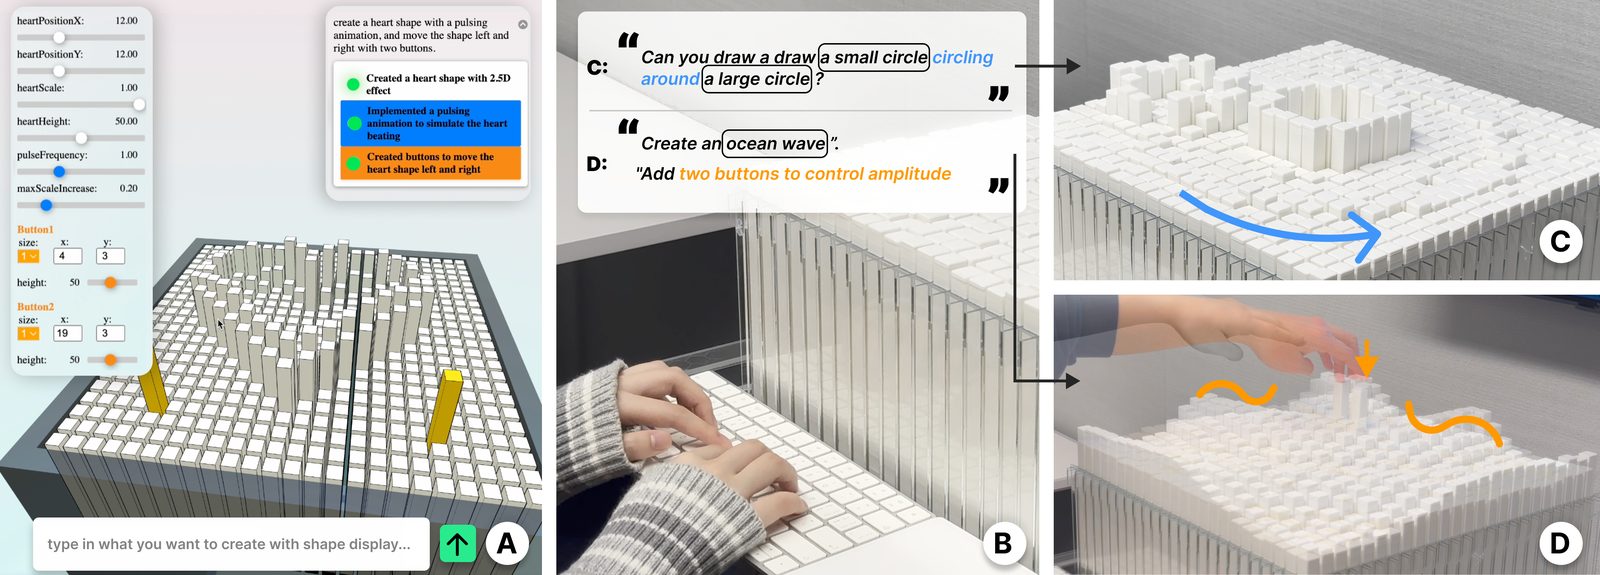
SHAPE-IT
Authoring shape-changing behaviors on a 24 × 24 pin display through natural-language commands.
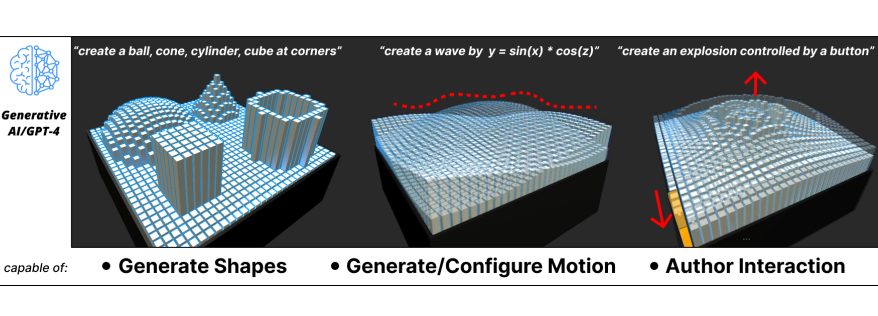
Multimodal interaction with AI shape displays
An early look at SHAPE-IT: GPT-4 turns natural-language instructions into dynamic shapes on a pin-based display.
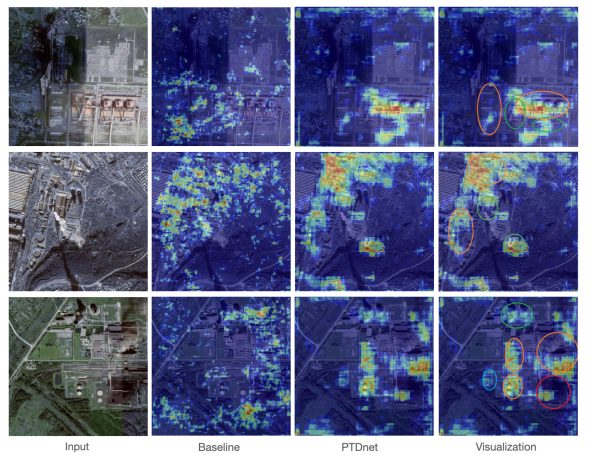
Part-based object detection in remote sensing
A weakly supervised, part-based detector for combined objects in remote sensing images that needs less labeling.
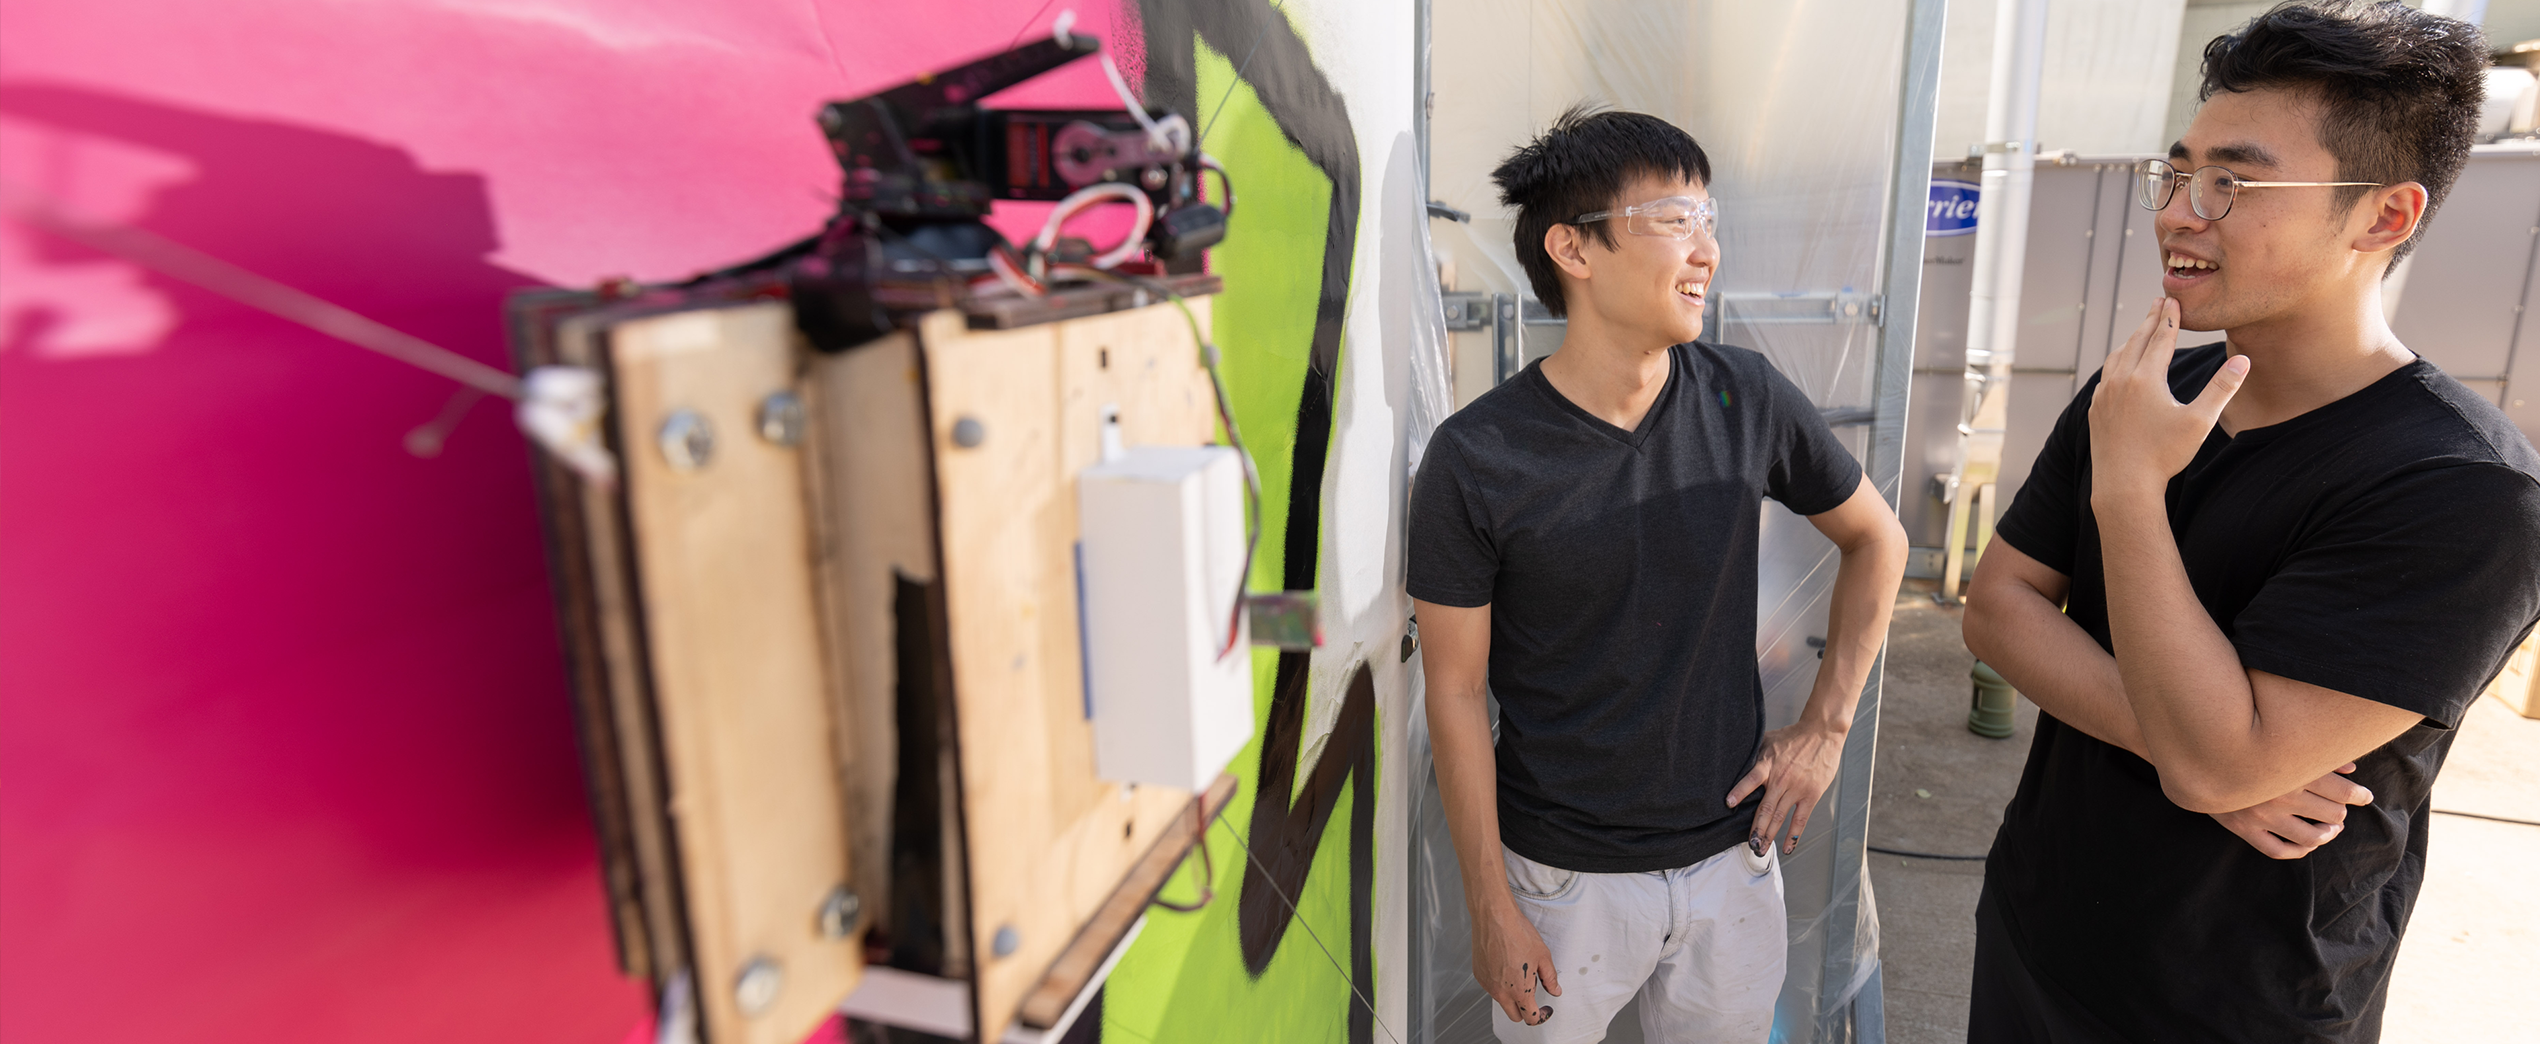
GTGraffiti: spray painting with a cable robot
A cable-driven robot that reproduces human graffiti painting motions, from motion capture to spray paint.
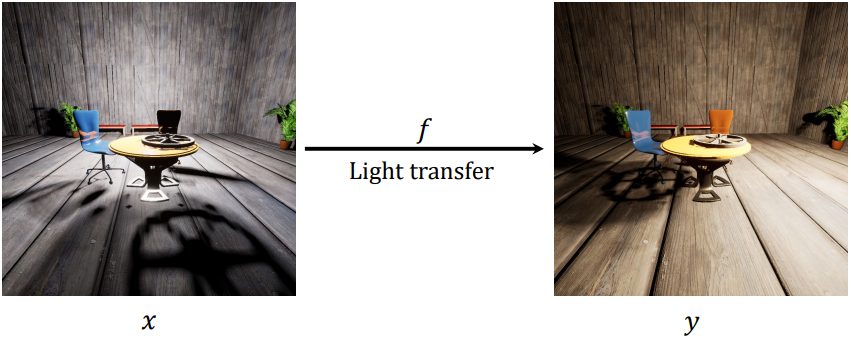
LTNet: depth-guided image relighting
Transfers lighting from a reference image to a target image with depth guidance, for the NTIRE 2021 relighting challenge.
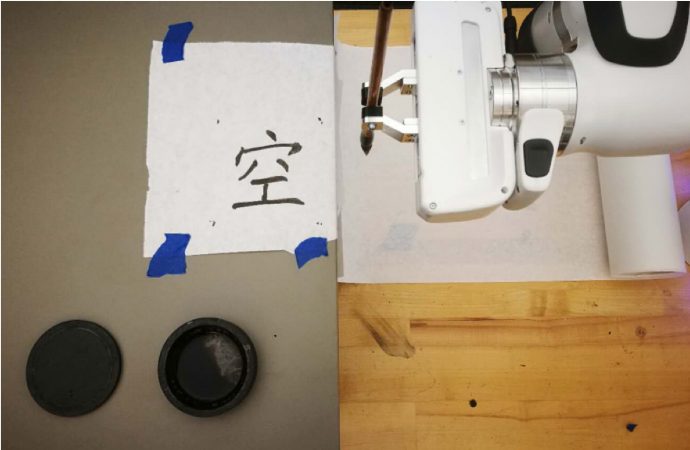
Stroke-optimized robotic calligraphy
Adapts the number of stroke control points to each character's complexity, so generated calligraphy follows the original more closely.
No projects with this topic yet.